Prerequisites
Make sure you followed either the Image classification or the FOMO: Object detection for constrained devices tutorials, have a trained impulse, and have installed the latest OpenMV IDE v5.0.0 or above.Compatible camera boards
- OpenMV Cam M7
- OpenMV Cam H7
- OpenMV Cam H7 Plus
- OpenMV Pure Thermal
- Arduino Portenta H7 + Vision shield
- Arduino Nicla Vision
- OpenMV Cam RT1062
- OpenMV N6
Deploying your impulse to an OpenMV device
Head over to your Edge Impulse project, and go to Deployment. From here you can create the full library which contains the impulse and all external required libraries. Select OpenMV library and click Build to create the library. Then download and extract the .zip file. Choose one of the following methods to upload the model and labels to your device.1. Upload to SD Card
This method works for small image classification / object detection models. Models loaded from the SD card are copied into RAM, so the device needs enough memory for both the model file and inference. Insert an SD card into your OpenMV camera and connect it to your computer. Copyei-model.tflite and ei-model.txt to the root of the SD card on the OpenMV Cam volume, as you would copy files to a USB drive. The model is available on the device at /sdcard/ei-model.tflite.
Next, run the script for your model as described in Running the example scripts below.
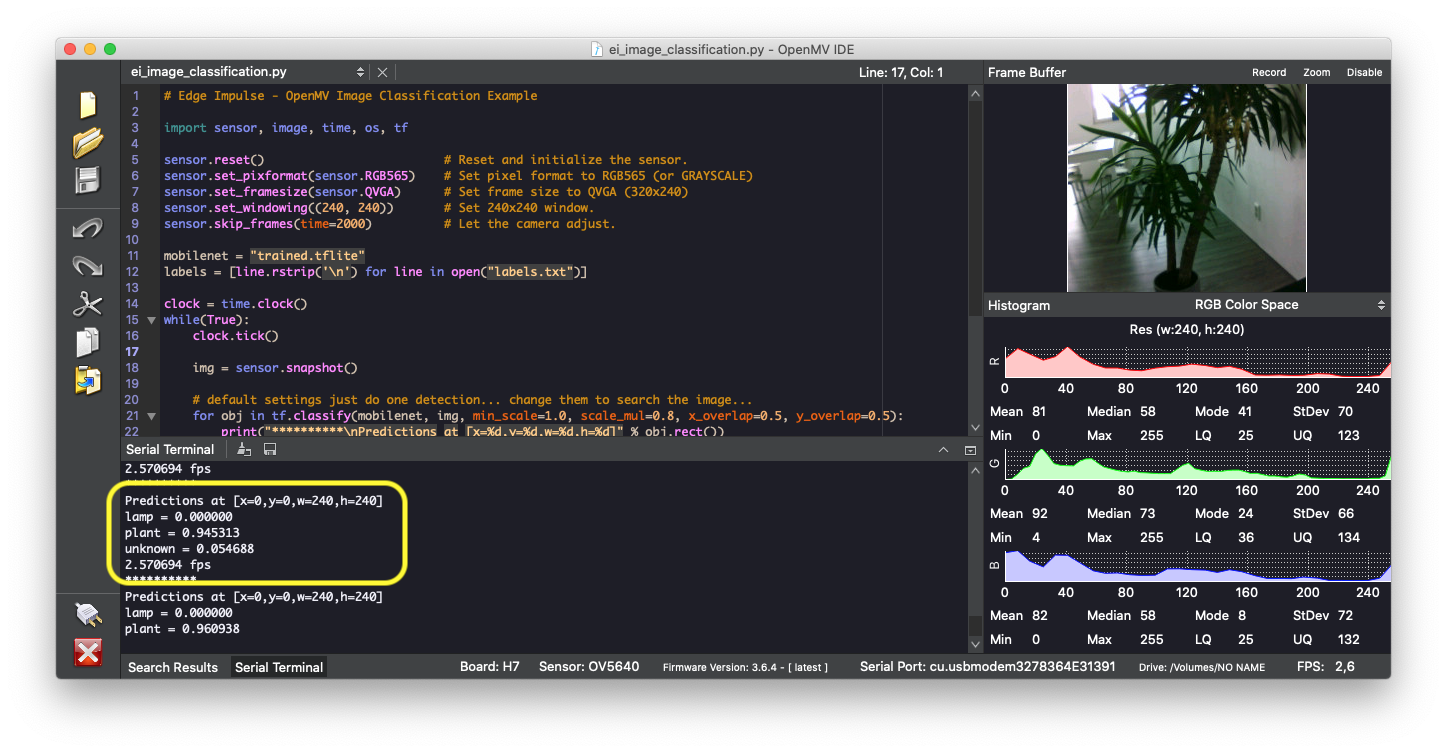
Running your impulse on your OpenMV camera.
2. Upload to ROM file system
On boards with ROMFS support, you can store the model and labels in the read-only file system mounted at/rom. The model’s weights stay in flash instead of being copied into RAM, leaving more RAM available for inference. The model still needs RAM for its intermediate tensors.
- Connect your camera to the OpenMV IDE.
- Select Tools > ROM File System > Edit ROMFS on OpenMV Cam to open the camera’s ROM file system.
- Add
ei-model.tfliteandei-model.txtto the root of the ROM file system. Check the usage readout to confirm that the files fit in the board’s ROMFS partition. - Click Commit and choose to write the updated ROM file system back to the camera.
- Set
MODEL_FROM_ROMFS = Truein the example script for your model, then run it as described in Running the example scripts below. For your own inference script, use the model path/rom/ei-model.tflite.
ml.Model constructor automatically loads labels from ei-model.txt when it is in the same directory as ei-model.tflite. Keep any post-processing required by your model in your inference script.
See OpenMV’s ROM file system editor guide and machine learning documentation for more details.
Running the example scripts
After uploadingei-model.tflite and ei-model.txt, open the script from the deployed folder in the OpenMV IDE. Depending on the model architecture, 1 of these should be included:
Leave
MODEL_FROM_ROMFS = False to load the files from the SD card, or set it to True to load them from /rom. Connect your camera in the IDE and click Play. View printed results in the serial terminal and detection overlays in the frame buffer viewer. For either object detection script, adjust threshold=0.4 in the active model-loading branch to change the minimum detection confidence.
Deploying your impulse as an OpenMV firmware
Troubleshooting
Only quantized (int8) models are supported
RuntimeError: Sensor control failed.